1
 →
vibe coded supermimic within 1h, LAFAN passed within 1.5 gpuh training
zita-ch/supermimic_vibed is an open-source project on GitHub, mainly written in Python. vibe coded supermimic within 1h, LAFAN passed within 1.5 gpuh training It currently holds 713 stars and 70 forks with 0 open issues, and was last pushed on an unknown date (repository created unknown).
Git Homed tracks it on the Today's Trending board.
Unofficial reproduction of *SuperMimic: Scaling Humanoid Whole-Body Control with One Differentiable World Model* (arXiv 2610.28480) — no official code is released, so everything here is implemented from the paper. Target experiment: the controlled LAFAN1 comparison (Fig. 4a): 40 G1-retargeted LAFAN1 clips (2.45 h), one GPU; the paper reaches evaluation normalized return 0.82 after 1.2 h on an H100.
Author: Chong Zhang (ETH Zurich). License: MIT.
Disclaimer: this repository was speed-vibecoded in 1 hour with an AI coding
assistant. It
deliberately does not live under any lab's organization, because the code is too much "slop"
for that: fast and unreviewed. Use it at
your own risk.
One G1 motion tracker for all 40 LAFAN1 clips, trained in only ~1.5 GPU-hours
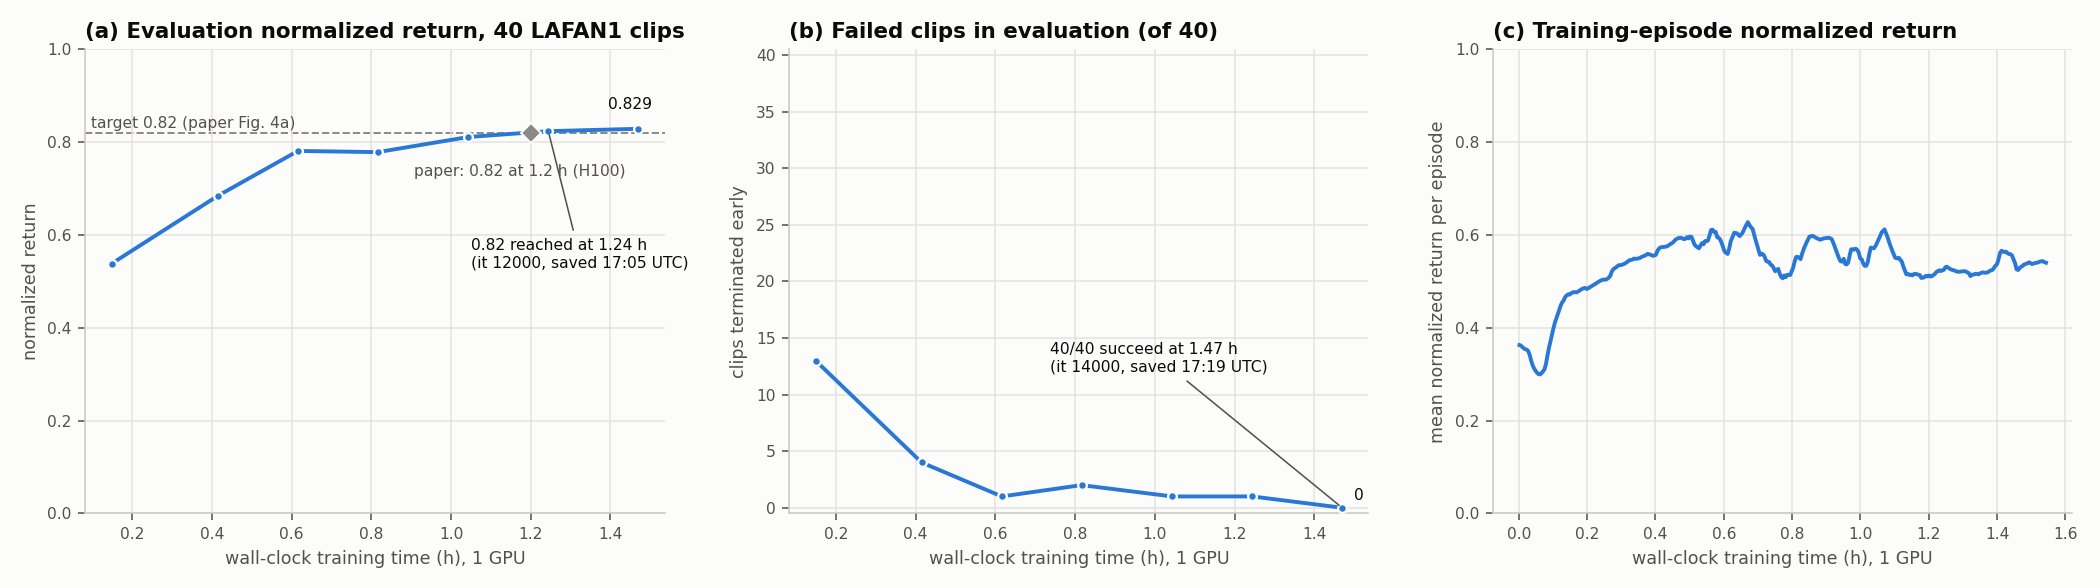
(1.47 h on a single RTX PRO 6000): evaluation return 0.829 with 0/40 failed clips.
For scale, the paper's PPO-in-simulator baseline does not reach return 0.82 within 18 h on up to
8 GPUs.
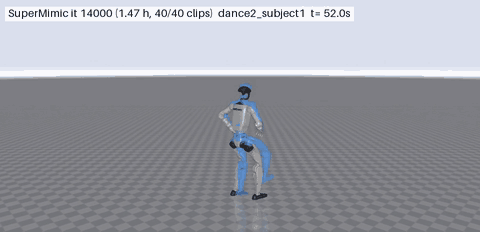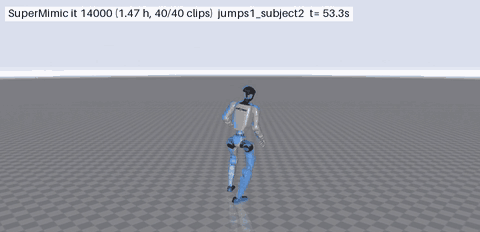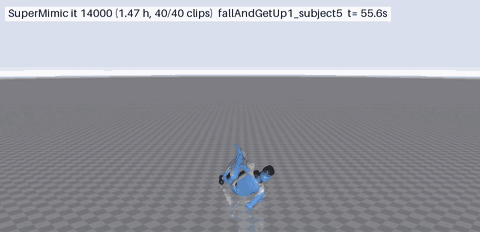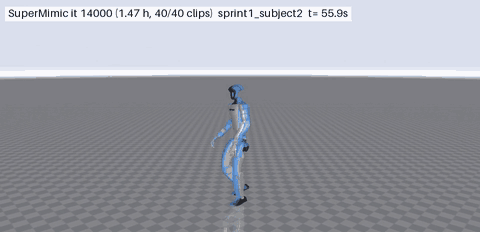
*Solid robot: the trained policy simulated in Isaac Lab with MuJoCo-Warp. Blue ghost: the reference motion. Clips: dance, jumps, fall-and-get-up, sprint.*
Progress and timestamps: MILESTONES.md.
| Path | What |
|---|---|
| IsaacLab/ | Isaac Lab main @ 46d6cc3 (VERSION 3.0.0), unmodified — cloned by tools/setup.sh, not tracked |
| docker/ | Dockerfile: supermimic:latest = isaac-lab-kitless:main-46d6cc3 (built from IsaacLab/docker/Dockerfile.kitless) + tmux, ffmpeg, gcc (for torch.compile); run_container.sh |
| data/ | not tracked; tools/download_data.sh fetches LAFAN1 G1 retargets (HF lvhaidong/LAFAN1_Retargeting_Dataset) and the G1 URDF/meshes, then builds g1_29dof.xml (MJCF) and the USD |
| supermimic/ | implementation (see below) |
| tools/ | setup, asset conversion, tests, benchmark, plotting, rendering, failure analysis |
| logs// | not tracked: train_log.csv, eval.csv, checkpoints, stdout |
| results/ | success curve and highlight GIF (full videos are rendered locally with tools/render.py) |
Neither Isaac Lab nor any data is included in this repository; the steps below fetch them.
Requirements: Linux, an NVIDIA GPU (tested: RTX PRO 6000 Blackwell, driver 580 / CUDA 13),
Docker with the NVIDIA Container Toolkit (docker run --gpus must work), ~20 GB of disk for the
images and ~0.2 GB for the data.
Physics: Newton with the MuJoCo-Warp solver (NewtonCfg(MJWarpSolverCfg(...))), no Kit, no PhysX;
50 Hz control, 4 substeps of 5 ms, implicitfast integrator, MuJoCo collision pipeline.
The code runs against Isaac Lab 3 main at commit
46d6cc3
(VERSION 3.0.0), unmodified, inside Isaac Lab's kit-less image (no Isaac Sim / Kit, no PhysX).
Newer main commits may work but are untested.
tools/setup.sh
which is equivalent to:
git clone https://github.com/isaac-sim/IsaacLab.git
git -C IsaacLab checkout 46d6cc3d7b115906fad12efd372fbf69f4e3d3ed
(cd IsaacLab && docker build -f docker/Dockerfile.kitless -t isaac-lab-kitless:main-46d6cc3 .)
docker build -t supermimic:latest docker/     # + tmux, ffmpeg, gcc, NVIDIA EGL vendor file
Then start the long-lived container (repository mounted at /workspace/supermimic):
docker/run_container.sh 0 128g # GPU index 0, 128 GB memory cap
| What | Source | License | Goes to |
|---|---|---|---|
| 40 LAFAN1 clips retargeted to the 29-DoF G1 (30 fps CSV: root pos, root quat xyzw, 29 joint angles) | HF lvhaidong/LAFAN1_Retargeting_Dataset, folder g1/ | CC BY-NC-ND 4.0 (Ubisoft La Forge) | data/lafan1_g1/*.csv |
| G1 description g1_29dof_rev_1_0.urdf + meshes (the model the clips were retargeted to) | same dataset, folder robot_description/g1/ | BSD-3-Clause (Unitree) | data/g1_description/ |
With the container from step 1 running:
tools/download_data.sh
This also caches Isaac Lab's official ground plane and textures in data/ground/.
For existing datasets, run bash tools/download_ground.sh once. This avoids a startup
stall in OmniClient's S3 download. No Docker rebuild is needed.
It downloads both, then converts the robot inside the container:
tools/urdf_to_mjcf.py compiles the URDF into data/g1_description/g1_29dof.xml (free-floating
pelvis), and tools/mjcf_to_usd.py converts that MJCF to data/g1_usd/g1_29dof/g1_29dof.usda,
which Isaac Lab spawns. The conversion is offline because the kit-less importers cannot run inside
an Isaac Lab process (see Deviations). Expected result:
data/
├── lafan1_g1/                  40 CSVs (dance, fallAndGetUp, fight, jumps, run, sprint, walk)
├── g1_description/
│   ├── g1_29dof_rev_1_0.urdf
│   ├── g1_29dof.xml            generated MJCF
│   └── meshes/*.STL            38 meshes
└── g1_usd/g1_29dof/            generated USD (+ payloads/)
Check: ls data/lafan1_g1 | wc -l prints 40, and the clips total 264,705 frames at 30 fps
(2.45 h). tools/test_env.py checks the converted robot against the reference motions (FK vs.
simulator should agree to ~1e-6):
docker exec supermimic python tools/test_env.py
CPUS=0-23 ./run_train.sh lafan1_main          # training in tmux session 'lafan1_main' (optional CPU pinning)
docker exec -it supermimic tmux attach -t lafan1_main
docker exec supermimic tmux new -d -s eval_main "cd /workspace/supermimic && python supermimic/evaluate.py --run_dir logs/lafan1_main --watch"
docker exec supermimic python tools/plot.py logs/lafan1_main --out results/success_curve.png
docker exec supermimic python supermimic/evaluate.py --run_dir logs/lafan1_main --ckpt logs/lafan1_main/ckpt_014000.pt --record traj.npz
docker exec supermimic python tools/render.py traj.npz out.mp4 --clips dance2_subject1 --seconds 10
The first iterations are slow while torch.compile builds its kernels (cached in .cache/).
Checkpoints are written every 2000 iterations to logs//; the eval watcher scores each on all
40 clips and appends to logs//eval.csv.
Evaluation return 0.824 at 1.24 h of training (paper: 0.82 at 1.2 h on an H100) and 0.829 with 0/40 failed clips at 1.47 h (iteration 14000).
supermimic/robot.py.
supermimic/motion.py, differentiable torch FK supermimic/kinematics.py
(matches the simulator's link poses/velocities to 1e-6).
supermimic/mdp.py.
supermimic/env.py.
supermimic/networks.py, supermimic/train.py.
supermimic/evaluate.py.
motion_anchor_ori_b — IMU-observable; no global position.
ulimit -v: Isaac Lab + Warp reserve ~430 GB of virtual--memory) instead. Rootless docker ignores --cpuset-cpus; pin CPUs with taskset
(CPUS=... in run_train.sh).
PhysxJointAPI schema not registered), so the USD is converted once, offline, by
tools/mjcf_to_usd.py (registers the importer's schema plugin first) and spawned with
UsdFileCfg(variants={"Physics": "mujoco"}).
The code in this repository is released under the MIT License.
Copyright (c) 2026 ETH Zurich, Chong Zhang.
→ →
 →
 →
 →
 →
 →
 →