1
 →
Project Quiver documentation, designs, and project artifacts.
Arrow-air/project-quiver is an open-source project on GitHub, mainly written in HTML. Project Quiver documentation, designs, and project artifacts. It currently holds 443 stars and 114 forks with 34 open issues, and was last pushed on 2026-09-22 (repository created 2024-12-05).
Git Homed tracks it on the Today's Trending board, currently at rank #67 with 42 new stars today.
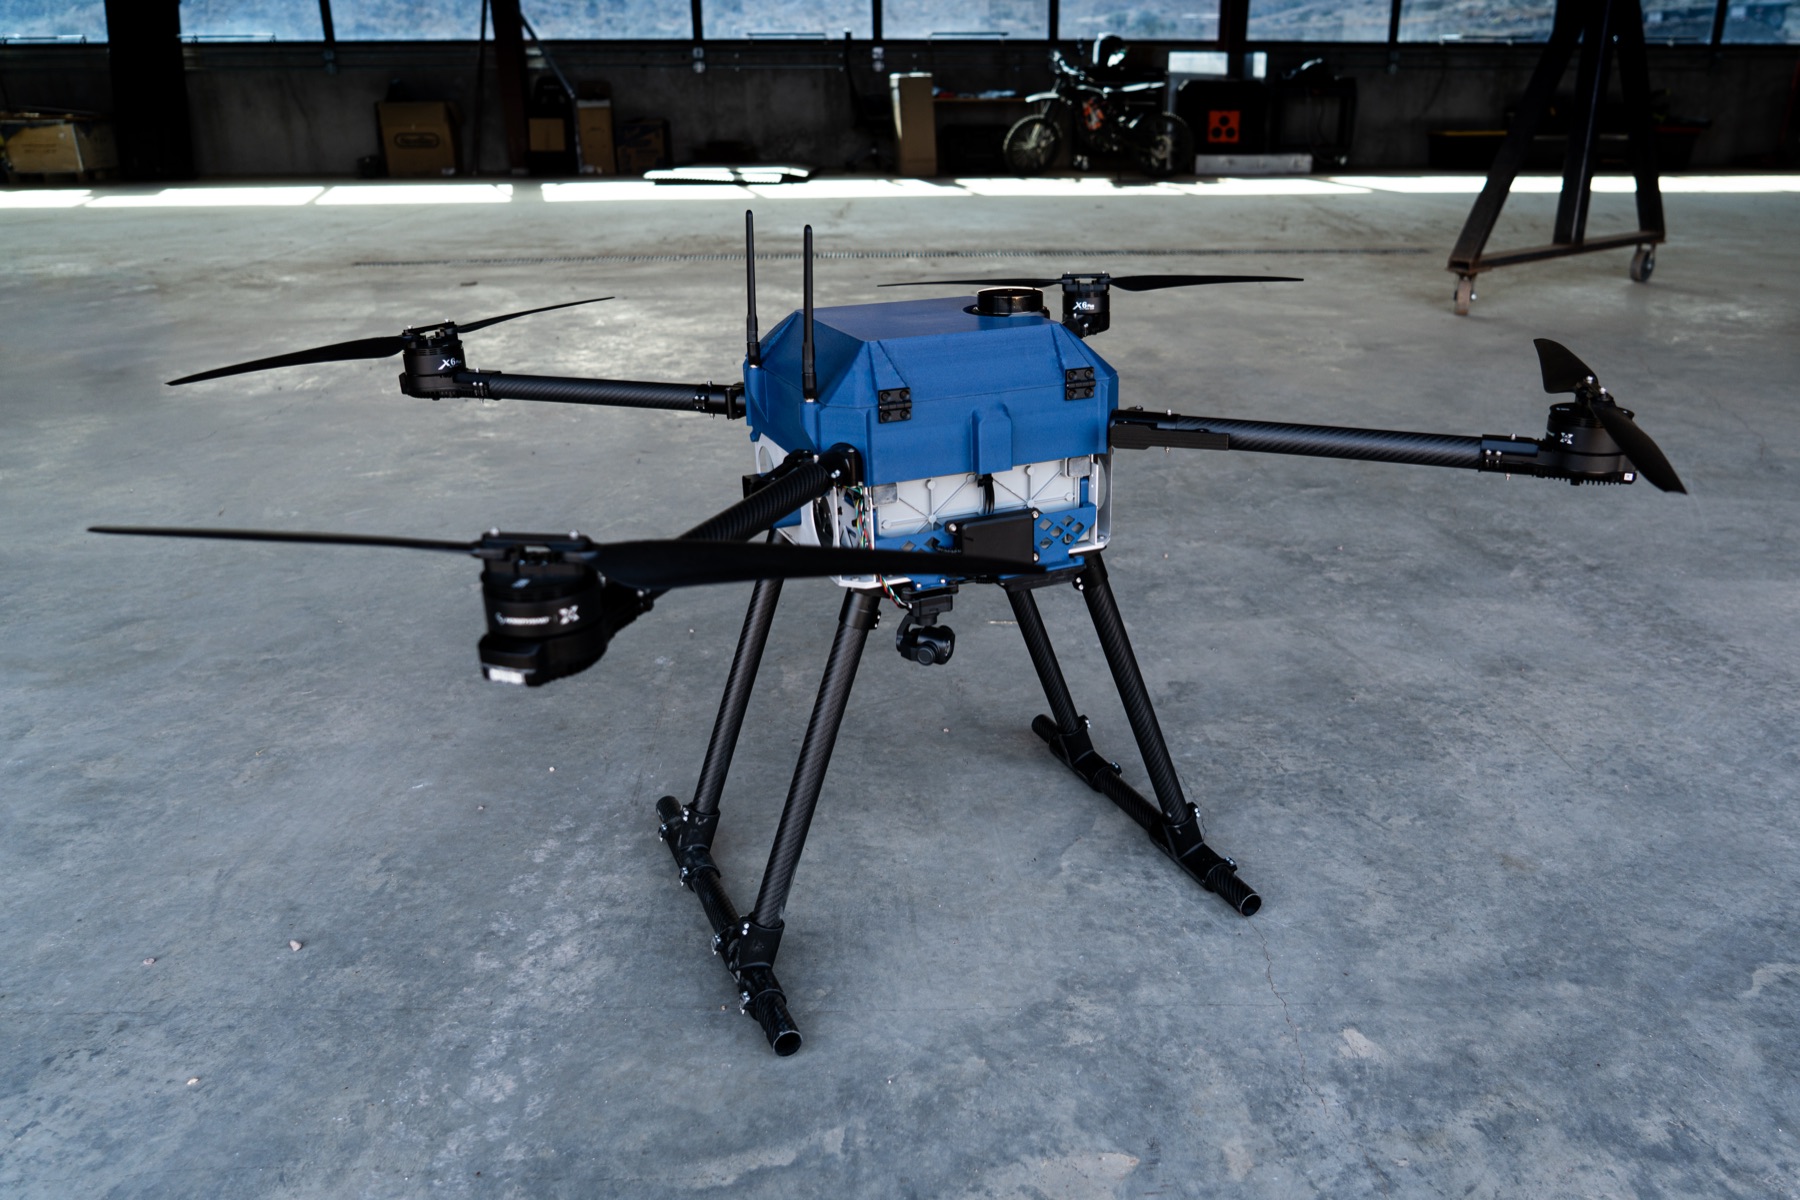
An open-source, modular quadcopter platform for developers and operators.
Project Quiver is a 25 kg MTOW drone with 5-8 kg payload capacity, three hot-swappable attachment interfaces, and a distributed electronics architecture. Built for reliability, field serviceability, and customization.
Developed by Arrow Air and released under the CERN Open Hardware Licence.
📖 Full Documentation — Platform overview, capabilities, and roadmap
The docs/ folder is hosted on the Arrow website.
| Resource | Description | |----------|-------------| | Assembly Guides | Step-by-step build instructions | | Engineering Reports | Technical details for each prototype | | Meeting Notes | Engineering call notes |
project-quiver/
├── docs/                    # Documentation (hosted at arrowair.com/docs/quiver)
├── src/
│   ├── quiver/              # CAD assembly — build123d Python package
│   ├── pcb/                 # KiCad PCB designs (4 custom boards)
│   ├── printing/            # 3D print profiles and settings
│   └── manufacturing/       # DXFs and cut sheets for CNC/laser
├── flight-test/             # Historical flight test logs
└── task-grant-bounty/       # Bounty and grant task specifications
The CAD source is a build123d Python package that composes STEP files into the full drone assembly. This enables programmatic CAD generation and version-controlled mechanical design. See src/quiver/ for details.
Want to build one? Start with the Assembly Guides.
Want to develop attachments? Check out:
Want a dev-kit? Dev-kit drones are available for loan to developers with promising projects. Join the Arrow Discord to learn more.We welcome contributions across:
CERN Open Hardware Licence Version 2 - Strongly Reciprocal (CERN-OHL-S)
→ →
 →
 →
 →
 →
 →
 →